A highly accurate sensor can still fail if its data does not seamlessly integrate with the city's broader traffic platform. Designing a successful radar video traffic sensor architecture requires much more than simply mounting hardware on a pole. Radar video fusion traffic detection must carefully define lane geometry and detection zones on actual roads, not just design drawings. True traffic sensor integration depends on establishing strict event schemas, time synchronization, and robust privacy controls from day one. Finally, smart transportation sensor commissioning must occur under representative, challenging conditions to guarantee a long-term deliverable of trusted, actionable traffic data.
Table of Contents
- Sensor and Site Geometry
- Geometry comes before analytics
- Define the data contract
- System Integration and Security
- Privacy and cybersecurity are architecture inputs
- Acceptance should resemble the road
- Operations and Lifecycle
- Survey each lane as a measurement problem
- Test the data path in layers
- Operate a measurement service after handover
- FAQs
Sensor and Site Geometry
Geometry comes before analytics
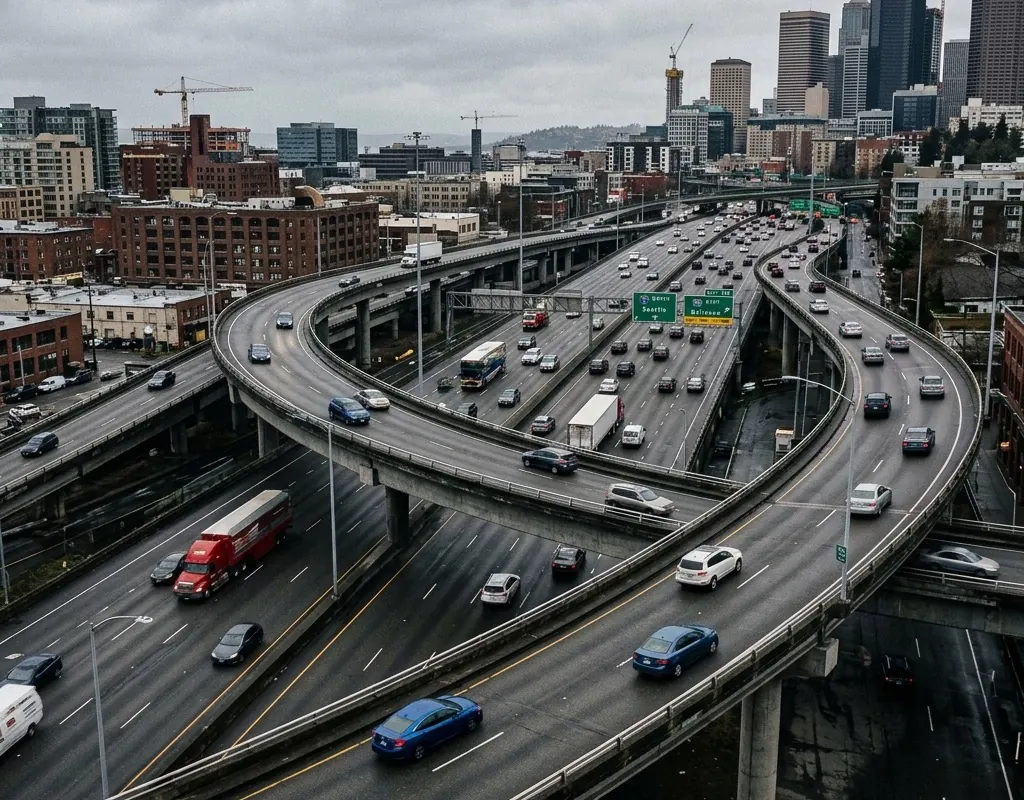
Curves, grades, lane changes, queues, large vehicles and roadside objects affect line of sight. Draw detection and evidence zones on the actual road geometry. Confirm mounting height, angle, maintenance access and the location of power and network equipment.
The target is not simply “coverage.” It is reliable measurement of the events the operator needs without ambiguous lane assignment or avoidable occlusion. The radar-video transportation sensor guide and current product catalog provide reference configurations for flow, access, speed and collision-warning applications. U.S. DOT’s connected and automated vehicle program provides broader standards and deployment context.
| Design layer | Decision to freeze | Acceptance check |
|---|---|---|
| Road geometry | Lanes, curves, grades and occlusion zones | Representative tracks mapped to correct lanes |
| Event model | Counts, classes, speed, alerts and evidence | Platform receives complete, non-duplicated events |
| Time | Authoritative source and timestamp format | Sensor, video and platform records correlate |
| Governance | Retention, access and disclosure rules | Roles and audit logs match the approved policy |
| Operations | Health, outage and maintenance workflow | Operators detect loss and recover the service |
Define the data contract
List the required counts, classes, speeds, tracks, images, video clips, alarms and health signals. Define timestamps, identifiers, coordinate conventions, retry behavior and how duplicate events are handled.
When those observations feed a work-zone warning, the traffic queue detection guide adds queue-tail location, coverage limits, message delay and stale-data handling. Flow measurements alone do not establish an accepted warning service.
Time synchronization deserves explicit design. A correct event with an inconsistent timestamp can break correlation, enforcement evidence and incident reconstruction.
System Integration and Security
Privacy and cybersecurity are architecture inputs
Decide whether identifiable imagery is required, who may access it and how long it is retained. Use role-based access, strong authentication, network segmentation, encrypted management paths and audit logs appropriate to the deployment, using the NIST Cybersecurity Framework 2.0 as a governance frame where appropriate.
Remote maintenance should not create an undocumented path around the operator’s security controls. Account ownership, update process and credential recovery belong in the acceptance pack. These choices connect directly to the smart city transportation architecture and, at controlled facilities, the critical infrastructure protection workflow.
Acceptance should resemble the road
Test representative vehicle mix, density, speeds, day and night conditions, glare and expected weather. Compare speed against a traceable reference and inspect lane assignment, classification and event latency.
Finish by testing device health, network loss, recovery and platform integration. The installation is complete only when operators can trust both the measurement and the workflow around it. Supporting checklists and documentation pathways are available in the OMNI UXV knowledge hub.
Where the primary deliverable is program-level volume, class, speed, or movement data rather than incident sensing, use the road traffic counter buyer guide to compare tubes, loops, radar, video, QA, and ground-truth acceptance.
Operations and Lifecycle
Survey each lane as a measurement problem
Create a lane and movement inventory before choosing mounting points. Include through lanes, turn pockets, shoulders, ramps, bicycle or pedestrian areas where relevant, queue spillback and the places where vehicles merge or change lane. For each movement, identify the measurement required and the likely occlusion or multipath source.
The survey should record proposed sensor coordinates, height, orientation, field of view, radar boresight, cable path, cabinet, power, network and safe maintenance access. Verify that a technician can service the installation without creating an unacceptable road hazard. Where one location cannot see all required movements reliably, the architecture should acknowledge the gap or use another view.
Use the traffic radar sensor buyer’s guide when the procurement needs radar-specific zones, stopped-vehicle behavior, controller fields and a ground-truthed commissioning matrix before the wider fusion layer is accepted.
| Survey output | Why it matters at acceptance |
|---|---|
| Lane and movement map | Provides the reference for assignment and count checks |
| Occlusion assessment | Identifies where vehicle type and traffic density may reduce performance |
| Evidence zones | Defines where images or clips should be captured |
| Communications path | Supports latency, outage and recovery tests |
| Maintenance plan | Confirms the system can be kept aligned and available |
Test the data path in layers
First validate the sensor locally against a traceable reference. Then verify the connector or protocol, followed by the receiving platform and operator workflow. This sequence makes it possible to locate an error. A correct local track that appears in the wrong lane on the platform may indicate mapping or coordinate transformation rather than sensor performance.
Use stable event identifiers and define how retries, delayed messages and duplicates are handled. Verify behavior across a restart or temporary network loss. For video evidence, confirm the relationship among trigger time, pre-event buffer, clip identifier and the traffic event.
Operate a measurement service after handover
Post-installation monitoring should expose device health, alignment change, clock drift, storage, network quality and data-volume anomalies. A sudden fall in counts might reflect traffic conditions, but it may also indicate a blocked view or failed connector. Define who investigates and how the period of uncertain data is marked.
Periodic checks should use representative samples by lane, time and vehicle class rather than a single aggregate accuracy figure. Preserve configuration changes and calibration results so data users know when a trend may have been affected by the sensing system. The long-term deliverable is trusted traffic data with a known operating history, not merely an installed pole.
FAQs
Why should road geometry be designed before sensor analytics?
Curves, grades, lane changes, queues, large vehicles and roadside objects change visibility and lane assignment. The required movements and evidence zones should determine mounting and sensing geometry.
What belongs in a traffic-sensor data contract?
Define events, tracks, classes, timestamps, identifiers, coordinates, images or clips, health signals, retry behavior, duplicate handling and the receiving platform’s acceptance rules.
What should radar-video commissioning test?
Test representative lanes, vehicle mix, speeds, density, day and night conditions, glare and weather, then verify time, event mapping, privacy controls, network loss, recovery and operator workflow.