A side-scan sonar price should be compared at the level of a complete survey capability: target-detection requirement, towfish and frequencies, cable and handling, positioning, topside hardware, software, vessel integration, calibration, contacts, deliverables, training, and support.
Table of Contents
- Define the Target and Coverage Requirement
- Choose Towfish, Hull, ROV, or Autonomous Deployment
- Price the Complete Acquisition Package
- Account for Positioning, Calibration, and Data Quality
- Model Survey-Day Economics
- Normalize Supplier Quotes and Data Rights
- Prove Detection and Reacquisition in Acceptance
- FAQs
Define the Target and Coverage Requirement
Name the smallest relevant target, expected relief, material and orientation, bottom type, water depth, search width, probability or confidence objective, positioning requirement, and final product. Wreck search, debris clearance, cable-route reconnaissance, habitat backscatter, security search, and engineering inventory do not need the same sonar.
Side scan creates an image from acoustic return and shadow. NOAA explains that it supports seafloor object detection and recognition, while most systems do not provide depth by themselves in its hydrographic equipment overview. Add bathymetry when the decision requires elevation rather than treating a compelling image as a 3D measurement.
Specify coverage as lines, swath overlap, target ensonification, gaps, nadir treatment, turns, exclusions, and contact reacquisition. The purchase requirement should link sonar performance to the actual tow altitude, range scale, speed, bottom and target.
Choose Towfish, Hull, ROV, or Autonomous Deployment
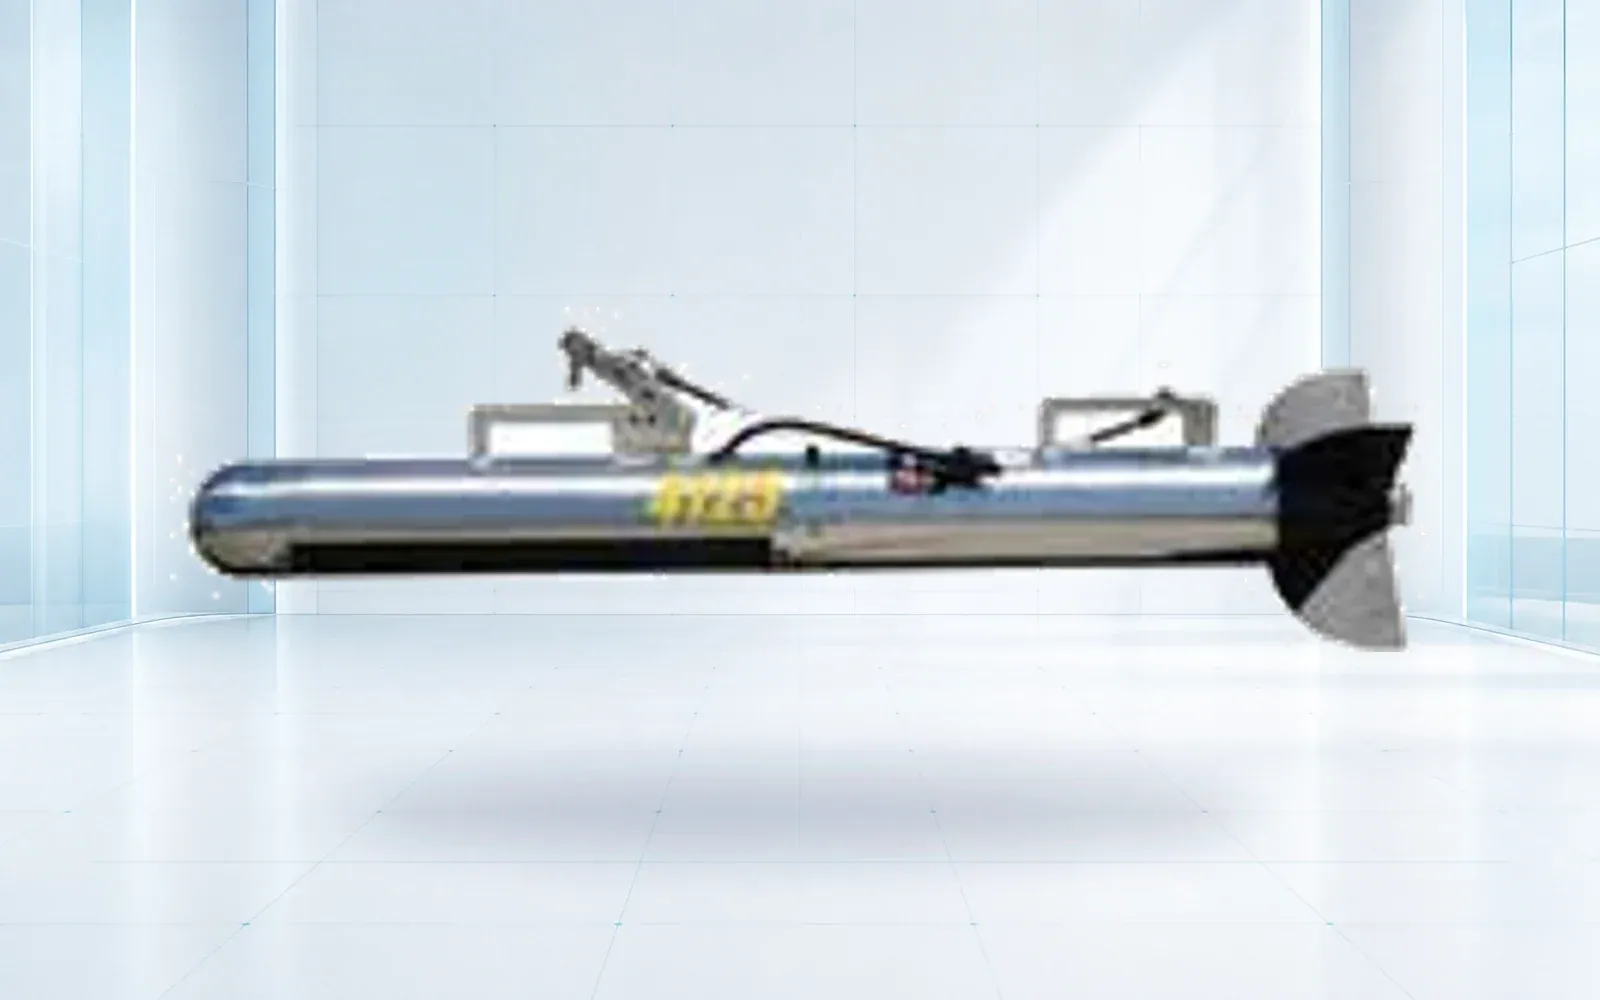
A towed fish can move the sensor closer to deep seafloor and isolate some vessel effects, but needs cable, winch, layback estimation, safe deck handling, altitude control, and turn planning. Hull mounting simplifies deployment but may place the sensor farther from the bottom and expose data to motion, bubbles, noise, and geometry limits.
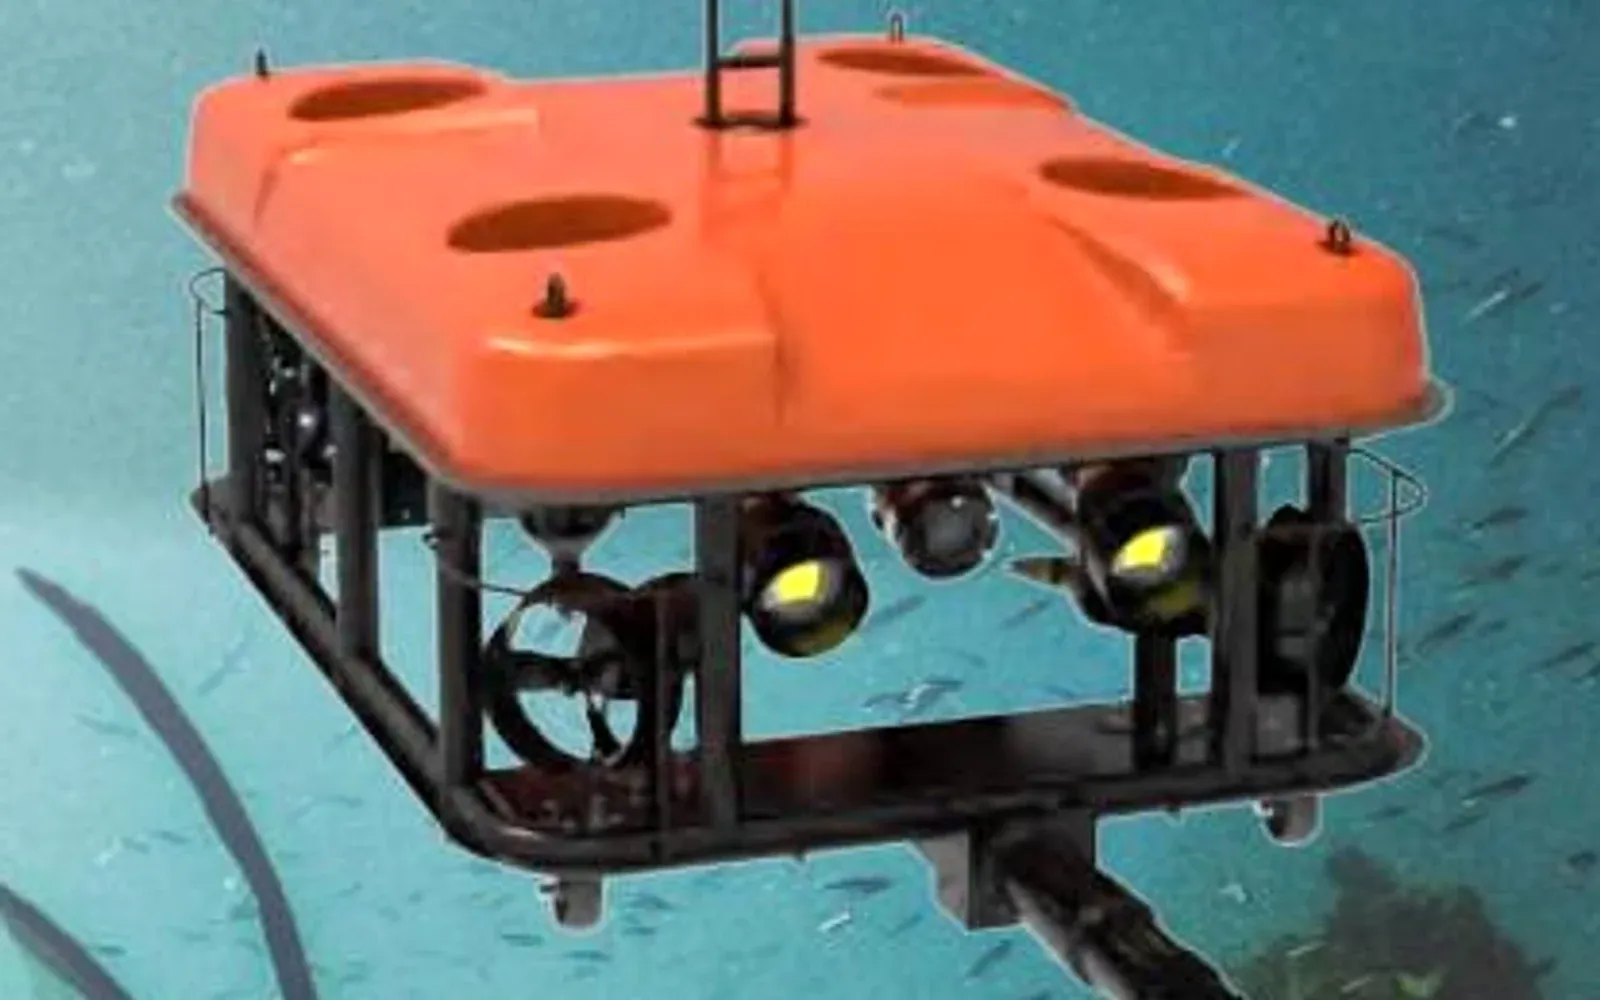
ROV mounting supports close investigation and controlled viewpoints but may cover less area and introduce vehicle/tether acoustics or motion. AUV deployment can provide stable near-bottom coverage without a live tether, with added navigation, mission, recovery, and data-offload requirements.
Select the architecture on survey economics and risk. Broad reconnaissance may find contacts for a later ROV inspection; a close asset inspection may never justify a towed search phase. The AUV side-scan survey guide covers autonomous survey design separately.
| Quote line | Scope to state | Common omission |
|---|---|---|
| Sonar/towfish | Frequencies, range, depth, channels and sensors | Installed configuration and data format |
| Tow cable | Length, conductors/fiber, strength, terminations and reserve | Repair kit, slip ring and load monitoring |
| Handling | Winch, level wind, sheave, davit and deck controls | Vessel foundation, power and certification |
| Navigation | GNSS, attitude, layback or acoustic positioning and time | Lever arms, latency and uncertainty |
| Topside/software | Control, acquisition, QC, mosaic and contact tools | License term, export and compute hardware |
| Deliverables | Raw, navigation, contacts, mosaics, report and metadata | Reprocessing rights and archive structure |
Price the Complete Acquisition Package
Require exact inclusions for towfish or transducer, cable, deck cable, winch, sheave, topside unit, computer, display, GNSS, motion or acoustic positioning, sound-speed tools where relevant, software, cases, spares, manuals, training, freight, commissioning, and acceptance.
The SNR900U side-scan sonar is a system starting point; the G70 ROV can support subsequent close observation. Verify interfaces, depth, data, mounts, positioning, and workflow for the selected deployment.
Ask who owns vessel integration. Power, grounding, electromagnetic and acoustic noise, cable paths, winch foundation, safe working load, deck layout, network, time synchronization, and sensor offsets can become material engineering and shipyard costs.
Account for Positioning, Calibration, and Data Quality
Contact location depends on navigation, time, sensor position, towfish layback or acoustic positioning, attitude, altitude, speed, slant-range processing, and interpretation. State the required contact-position uncertainty and how it will be tested. GNSS at the vessel is not automatically sonar position at the bottom.
NOAA’s Standard Ocean Mapping Protocol covers configuration, calibration, acquisition, target detection, QA/QC, uncertainty, processing, and mosaics. Use applicable guidance to write the workflow, then adapt it to the project’s governing standard and target.
The 2026 NOAA Hydrographic Survey Specifications and Deliverables ties claimed feature detection to computed target heights and operating geometry. A commercial project may use different criteria, but it should be equally explicit about what counts as a detected, positioned, and delivered contact.
Model Survey-Day Economics
Equipment price is one part of cost per searched area. Model mobilization, vessel, fuel, captain and deck crew, sonar operator, surveyor, weather, transit, launch/recovery, line turns, safe tow speed, swath, overlap, altitude control, re-runs, contact investigation, processing, reporting, and demobilization.
Wider nominal range can reduce line count but may weaken target detail, change grazing geometry, increase nadir or shadow issues, and complicate reliable detection. Higher frequency may improve detail but narrow the useful swath. Use a production model that meets the target criterion rather than maximizing square kilometers.
Include failure and downtime: cable damage, connector faults, winch problems, towfish loss risk, corrupted data, navigation gaps, software licenses, and unavailable repair parts. Price critical spares and recovery plans against vessel-day cost.
Normalize Supplier Quotes and Data Rights
Send all bidders one water-depth profile, bottom types, target definition, coverage area, vessel assumptions, positioning requirement, deliverables, support term, and acceptance plan. Label each item included, optional, excluded, or buyer-supplied. Separate perpetual and subscription software.
Confirm raw and processed formats, navigation, metadata, contact database, mosaics, settings, logs, and rights to reprocess. NOAA’s marine geophysical data guidance illustrates why documented formats and associated navigation matter for reuse and discoverability.
Compare purchase, rental, and service on an accepted-search-area or accepted-contact basis. A service price may include vessel and expertise; a sonar price does not. Normalize before declaring one option cheaper.
Prove Detection and Reacquisition in Acceptance
Bench tests should verify configuration, frequencies, channels, sensors, file creation, time, interfaces, software, logs, spares, and health monitoring. Wet acceptance should use representative depth, bottom, acoustic environment, speed, range, tow altitude, turn, and vessel installation.
Use known targets near the required detection limit and clean areas. Score detection by scenario, contact height or classification where required, location error, coverage, nadir gaps, artifacts, false contacts, tow stability, data integrity, processing, mosaic quality, and target reacquisition by the planned follow-up method.
Document the validated operating envelope and retest triggers for towfish, frequency, cable, winch, navigation, vessel, software, and processing changes.
Review the underwater systems portfolio, port and water security solution, and technical resources, then contact OMNI UXV with target size, depth, bottom, area, deployment architecture, positioning, deliverables, and wet-test design.
FAQs
How much does a side-scan sonar cost?
There is no useful universal figure because frequency, range, depth rating, towfish, cable, winch, positioning, software, vessel integration, spares, training, and deliverables change the complete system price.
Does side-scan sonar measure water depth?
Conventional side scan primarily images acoustic reflectivity and shadows; it usually does not provide bathymetry. Projects often combine it with single-beam or multibeam sonar when depth is required.
Is a higher-frequency side scan always better?
No. Higher frequency generally supports finer detail at shorter range, while lower frequency can cover wider swaths. The target, water depth, tow altitude, speed, coverage, and survey economics should decide.
How should side-scan sonar be accepted?
Use representative bottom, depth, tow geometry, speed, range and known targets, then score target detection, contact location, coverage, artifacts, navigation, file integrity, reacquisition, and deliverable production.